AP-H7
One autopilot for every airframe.
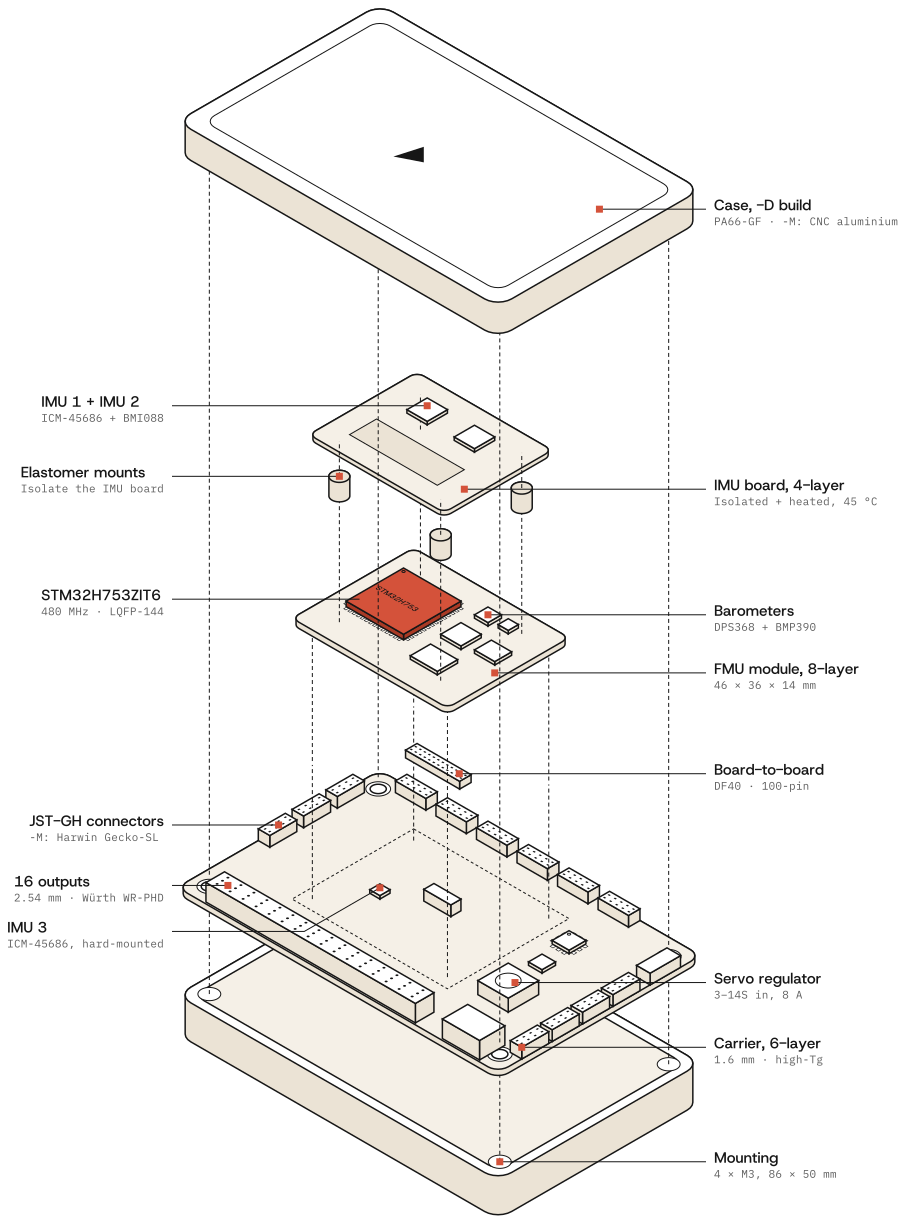
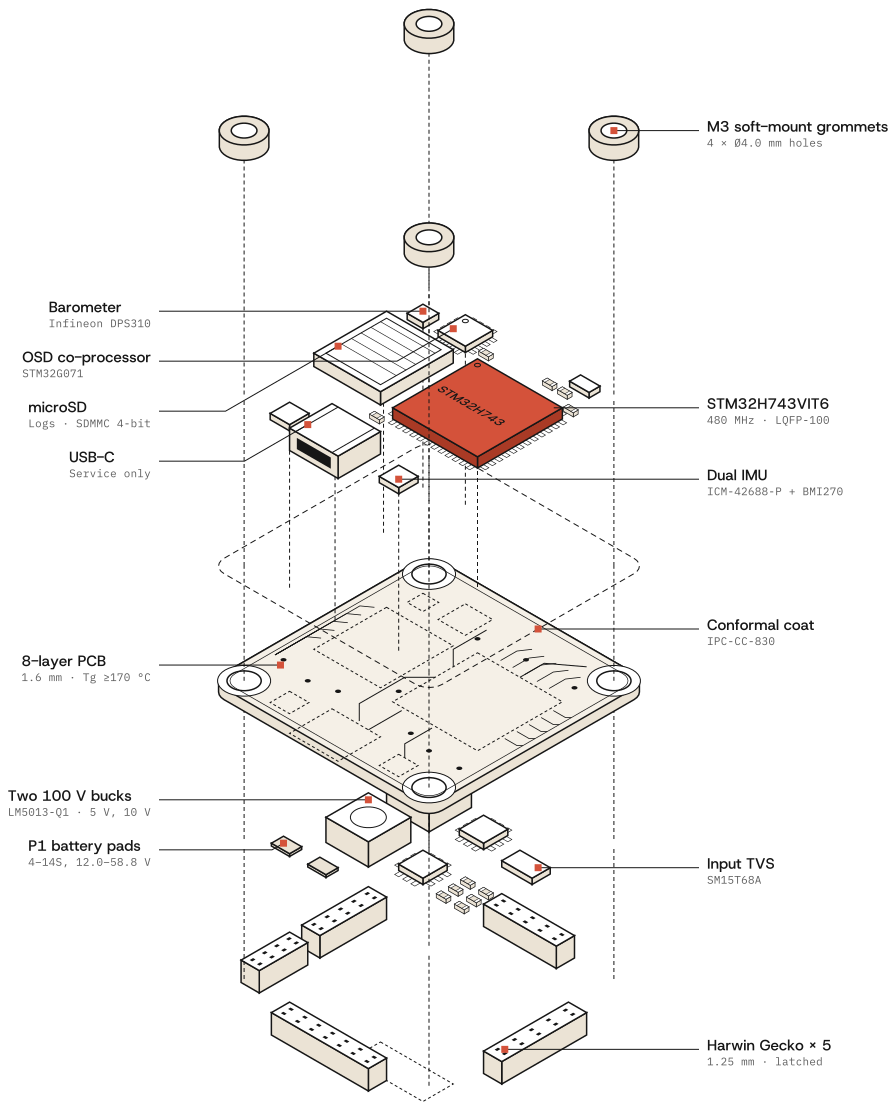
A cased STM32H753 autopilot for fixed-wing, VTOL, and multirotor UAS, running PX4 or ArduPilot. A calibrated FMU module plugs into the carrier.
Three IMUs sit in separate bus and power domains. Two ride on an elastomer-isolated board heated to 45 °C, and the third is hard-mounted with a ±32 g range for launch and landing shock. Lose a power module and the autopilot stays up: two 5 V inputs swap through an ideal-diode OR without a reset. A stalled servo can't brown out the FMU, because servo current never flows through its supply. A signed bootloader and an NXP SE051 secure element hold keys and device identity.
Request spec sheet